Completed
Self-Balancing Electric Vehicle
A two-year high school project: a self-balancing personal vehicle across two hardware revisions, built with limited tools and a lot of iteration.
Quick overview In plain language
What it does
A rideable board with a single central wheel. It continually adjusts its motor to help the rider balance.
My contribution
I built two versions, working on the frame, battery, electronics, and the control system that keeps the board level.
Where it stands
Both hardware revisions are completed. The page shares the development story and lessons from building them.
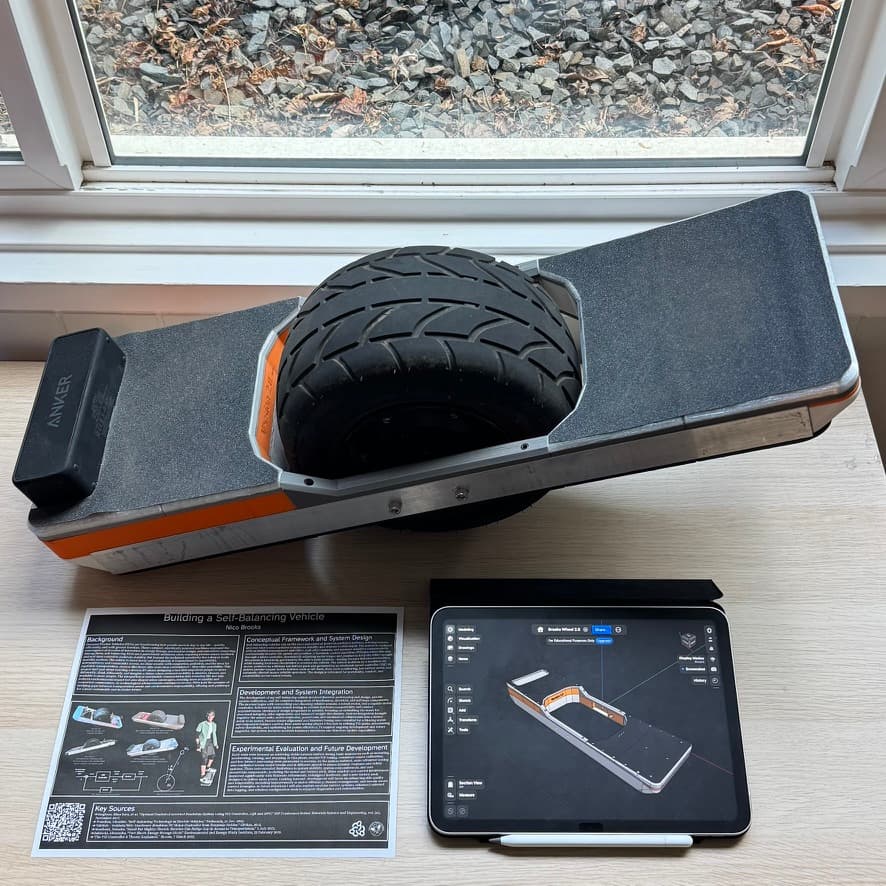
Overview
This was where I learned control theory and mechanical design by building something that could actually stay upright. MK1 got the balance loop working. MK2 cleaned up the frame, battery pack, and packaging. Most of what I understand about closed-loop systems and fabrication started here.
Design documentation
The system overview below explains the project at a high level. Detailed design files are shared selectively. For a technical review or collaboration, get in touch to discuss access.
How it works
System overviewBlock diagram
A simplified view of how sensing, control, and movement work together to keep the vehicle balanced.
Balance control
- Orientation sensingMeasure how the vehicle is tilted
- Balance controllerDetermine a corrective motor response
- Motor + wheelChange the vehicle’s motion
Keeping the vehicle balancedFlow chart
- 01Measure tilt
- 02Calculate correction
- 03Drive the wheel
- 04Measure the response
The new orientation feeds back into the next correction.
Explore another build
BrooksBoard